
Erkan Teskancan
Corporate
- Thread Author
- #1
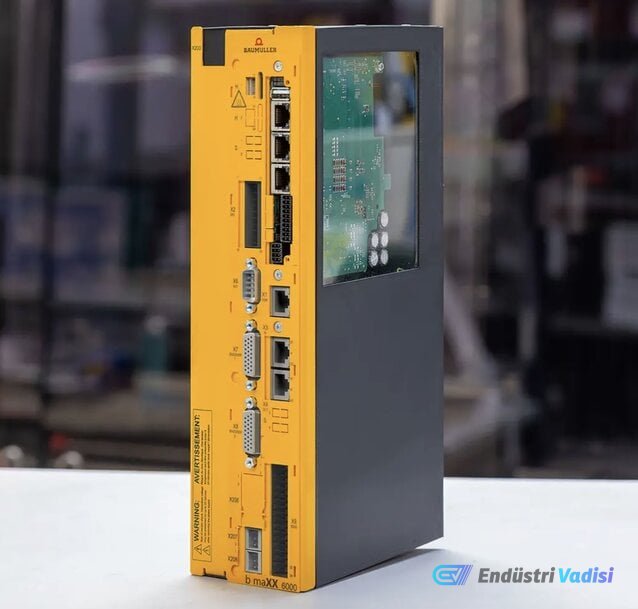
✨ Next-Generation Control for Smart Machines
Baumüller has expanded its automation and drive technology portfolio with the b maXX drivePLC. This drive-integrated control unit is designed for motion control requiring high synchronization and for decentralized machine topologies. It combines programmable logic control, motion coordination, and technology-specific software within the servo drive housing, executing closed-loop tasks in real-time control cycles down to 250 µs.
🧠 Decentralized Intelligence and Multi-Axis Control
Moving automation control to a decentralized structure enables the breakdown of complex production lines into autonomous, pre-assembled mechatronic modules. This allows sub-units to be designed, parameterized, and pre-commissioned independently. The b maXX drivePLC operates as an EtherCAT Master, directly commanding dependent servo converters and peripheral I/O modules. This enables the creation of distributed machine clusters without the need for a central PLC.
🌐 Connectivity, Software Flexibility, and Cybersecurity
The platform operates on a Linux-based runtime environment designed for open communication and custom application deployment. It supports industrial interfaces such as OPC UA, MQTT, EtherCAT, and Industrial Ethernet, enabling integration between physical machines, manufacturing execution networks, and enterprise cloud systems. Furthermore, the embedded security architectures within the platform comply with industrial cybersecurity standards, helping equipment manufacturers meet the requirements of the European Union Cyber Resilience Act (CRA).
⚙️ Technical Details
Drive-integrated PLCs eliminate fieldbus jitter and propagation delays by co-locating the motion trajectory generator on the same digital signal processor (DSP) or field-programmable gate array (FPGA) that manages the pulse-width modulation (PWM) switching inverter. High-speed internal dual-port RAM interfaces allow the embedded PLC task to synchronously query instantaneous phase currents, DC link voltages, motor torque feedback, and encoder position vectors within the current controller loop interval (typically under 62.5 microseconds). Operating as an EtherCAT master using Distributed Clocks (DC) enables multi-axis synchronization between dependent servo nodes with jitter tolerances under 1 microsecond. To comply with the European Union Cyber Resilience Act (Regulation EU 2024/2847) and IEC 62443-4-2 industrial security requirements, embedded Linux runtimes include hardware-enforced secure boot via a physical Root of Trust (RoT), encrypted persistent memory partitions, role-based access control (RBAC), and standardized Software Bill of Materials (SBOM) tracking to protect against unauthorized firmware modifications and remote network attacks.