
Mucitler Elektrik
Corporate
- Thread Author
- #1
✨ Revolutionizing Robotic Gripping Systems
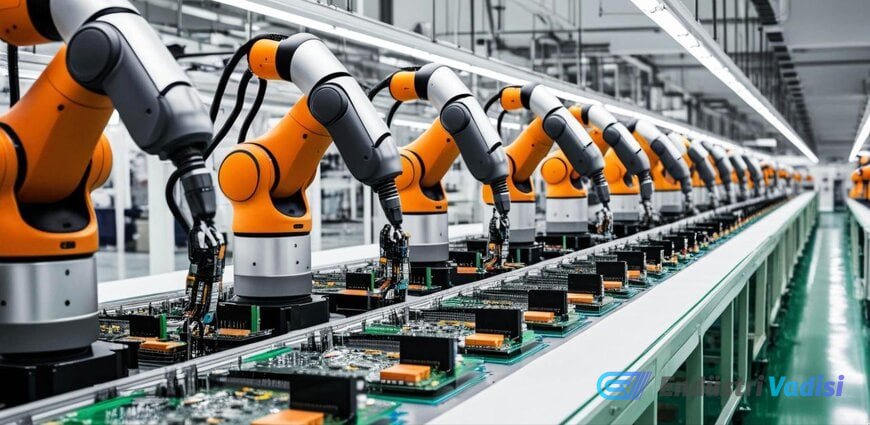
Modern production lines require robotic systems that can adapt to varying workpieces. To meet this demand for flexibility, Festo has developed integrated End-of-Arm Tooling (EOAT) solutions that combine artificial intelligence, vision-guided motion, and pneumatic, electric, and vacuum gripping technologies. As a result, robotic systems can now not only grip reliably but also determine what to grip, where, and how.
🛠️ Simplicity with Integrated Architecture
Festo goes beyond merely providing gripping components by offering complete end-of-arm tooling solutions. This approach supports users throughout the entire process, from selection to design, integration, and commissioning. Standardized interfaces, engineering tools, and software modules simplify integration into systems from different robot manufacturers, reducing engineering and commissioning efforts, thereby enabling faster and easier implementation of robotic applications.
🧠 Artificial Intelligence and Vision-Guided Motion
It is becoming increasingly important for robots to recognize objects and determine appropriate gripping strategies on their own. Festo addresses this need with software and artificial intelligence. "Vision Guided Motion (VGM)" combines intelligent image processing with precise path guidance. Components are detected regardless of their position and orientation, then processed with pre-configured programs such as gluing or screwing, or transferred to the next station. This reduces mechanical adjustments and engineering effort while increasing process reliability and productivity.
For unknown or changing objects, the AI-based "GripperAI" software helps the robot recognize objects and determine suitable gripping points and strategies. This allows gripping processes to adapt more flexibly to different objects and reduces the programming effort required for new applications.
🍄 Automated Mushroom Harvesting: An Application Example
Demonstrating the practical interaction of artificial intelligence and intelligent automation, the "Mushroom Harvesting Unit" is designed for the automatic harvesting of pressure-sensitive mushrooms. This solution combines image processing with motion and gripping technology. Thanks to AI-supported image processing, the system detects and evaluates mushrooms and determines the optimal harvesting time. A high-precision gantry system positions the gripper over the target, while a rotary axis at the wrist and soft gripping technology ensure damage-free harvesting.
🌍 Cross-Industry Applications
Automated mushroom harvesting is just one example of what modern end-of-arm tools can achieve. Festo's gripping and vacuum solutions are used in many sectors, including the automotive industry, electronics manufacturing, packaging technology, food industry, laboratory automation, and machine tools. Whether fragile, heavy, small, irregularly shaped, or randomly positioned, very different workpieces require suitable gripping principles, and Festo implements these with its end-of-arm tooling solutions.
💡 Technical Developments and Standards
In industrial robotics, end-of-arm tools have evolved from simple pneumatic parallel grippers to mechatronic subsystems incorporating force-torque sensing, embedded controllers, and vision modules. Traditional bin picking and variable part handling relied on deterministic 3D CAD matching, which often struggled with deformable, organic, or reflective objects. Modern AI-powered grasping algorithms, trained on synthetic and real-world data, enable robots to generalize grasping poses for previously unseen objects without prior CAD models. Furthermore, standardized mechanical and communication interfaces such as ISO 9409-1 mounting flanges and IO-Link connectivity have become an industry standard, enabling plug-and-play interoperability between tool providers and six-axis and collaborative robot manufacturers.