
Ahmet Ö.
Corporate
- Thread Author
- #1
🤖 End to Robotic Integration Challenges!
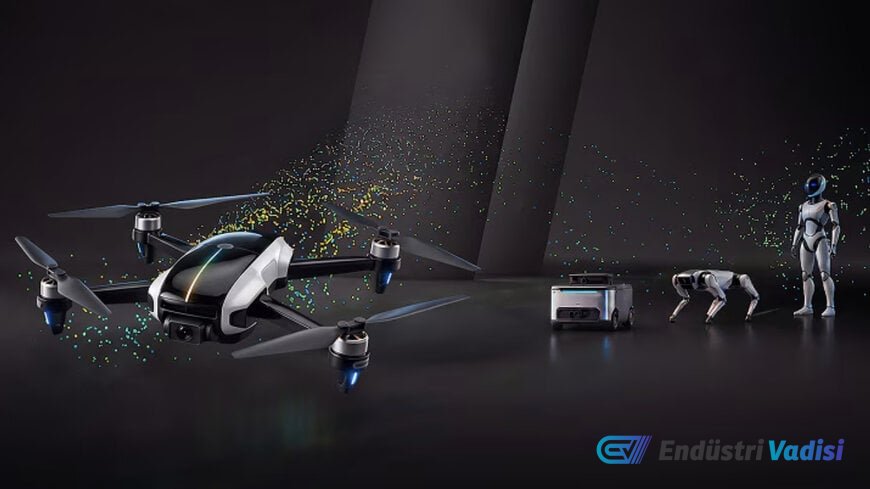
NXP Semiconductors has introduced a unified robotics platform to resolve integration bottlenecks between real-time control, sensing, and autonomous physical AI systems. Integrating heterogeneous robotic subsystems, ranging from high-throughput neural processing to deterministic motor control for autonomous systems operating in industrial and commercial environments, often poses significant challenges. To overcome these cross-domain engineering hurdles, the platform establishes a structured foundation that coordinates sensing, real-time actuation, machine intelligence, and secure networking in uncrewed platforms and industrial automation systems.
⚙️ Hardware Decoupling and Deterministic Communication Architecture
Autonomous robotic architectures require separate processing domains to manage tasks with sharply different timing constraints. Real-time motor commutation and trajectory execution cannot share execution pipelines with non-deterministic AI workloads without risking control instability. The unified robotics platform addresses this issue with its Neural Axis Architecture. This approach separates vision-based edge processing from low-latency control loops while maintaining secure data transfer between subsystems.
By combining an open-source, modular software development kit (SDK) with pre-validated reference modules, developers can build foundational robotic behaviors sequentially. Control loops can be independently evaluated within isolated hardware nodes before integrating perception-driven navigation stacks. Communication between distributed processing nodes relies on embedded industrial and automotive networking topologies, including single-pair Ethernet interfaces that reduce payload weight and cabling complexity in mobile robotic airframes and mobile robotic chassis.
🛠️ Modular Reference Designs and Subsystem Specifications
The initial hardware deployment targets autonomous aerial vehicles using four modular reference elements, each addressing distinct computational and control profiles:
- High-Level Perception and Autonomous Computing: The NavQ95 compute node leverages the i.MX 95 applications processor to run vision processing, mapping algorithms, and higher-level task planning duties.
- Flight Management and Real-Time Actuation: The Tropic Vehicle Management Unit/Flight Management Unit (VMU/FMU) integrates the i.MX RT1064 crossover microcontroller (MCU), which manages real-time stabilization routines and telemetry parsing.
- Intelligent Sensor Integration: The sensor aggregation node is built on the MCX N947 microcontroller and uses an automotive-grade 100Base-T1 physical layer to deterministically connect edge sensors over single-twisted pair cabling.
- Motor Actuation: Actuation is performed via an MCX A13 MCU-based AM32-compatible electronic speed controller (ESC), designed to manage high-frequency pulse width modulation (PWM) signals for brushless motor commutation.
💻 Software Abstraction Layers and Robotic Operating Systems
Standardizing embedded robotic software across disparate processing architectures often requires extensive driver adaptation. The modular SDK addresses this fragmentation by packaging device drivers, middleware, and board support packages compatible with widely adopted open-source frameworks.
The software stack integrates ROS 2 for high-level node orchestration and inter-process messaging, the PX4 autopilot software stack for navigation guidance and aerodynamic stabilization, and the Zephyr real-time operating system (RTOS) for deterministic, resource-constrained microcontrollers. This abstraction model ensures that silicon-level implemented safety measures and hardware security functions operate continuously, independent of higher-level application code behavior.
🏭 Industrial and Operational Applications
The platform targets multi-rotor inspection drones, last-mile delivery UAVs, service robots, and autonomous mobile robots (AMRs) operating in warehouse logistics, industrial inspection, and automated agriculture.
For example, in automated warehousing, deploying automated guided platforms requires balancing high-speed optical obstacle detection with certified safety stop functions. The use of validated embedded blocks allows engineering teams to compress initial prototyping times from several months to standard validation cycles, accelerating deployment in physical environments that require continuous operational reliability.
💡 Additional Information: Heterogeneous Computing and Safety Standards
In the embedded robotics sector, heterogeneous computing architectures are increasingly replacing monolithic compute boards. As physical AI progresses towards autonomous collaborative machines, design teams face increasing compliance requirements under safety standards such as IEC 61508 and ISO 13849 for industrial machinery, and emerging safety frameworks for uncrewed aerial systems.
In comparative robotic development architectures, single-board computing solutions typically adopt one of two industry models: centralized computing platforms that route sensor data and motor driver logic directly to high-power processing units (monolithic system-on-chips like the NVIDIA Jetson series), or split-domain architectures that separate real-time microcontrollers from neural network accelerators (paired architectural configurations using STMicroelectronics STM32 MCUs with separate host vision processors).
Centralized models offer significant GPU-centric inference capabilities for spatial computing but routinely encounter difficulties maintaining microsecond-level determinism for motor control without dedicated co-processors. Conversely, custom discrete designs using standard general-purpose microcontrollers often require significant engineering resources to implement communication stacks, secure boot flows, and real-time network drivers between disconnected components.
The integration of 100Base-T1 Ethernet directly into the sensor aggregation layer reflects a broader industry movement towards automotive Ethernet standards, replacing legacy UART and SPI communication links. This transition provides 100 Mbps full-duplex data rates over unshielded single-twisted pairs, offering higher bandwidth for multi-directional lidar, radar, and imaging sensor networks while reducing electromagnetic interference (EMI) in dynamic motor environments.